MDD025A-N-100-N2K-040ME0
MDD Synchronous Motors
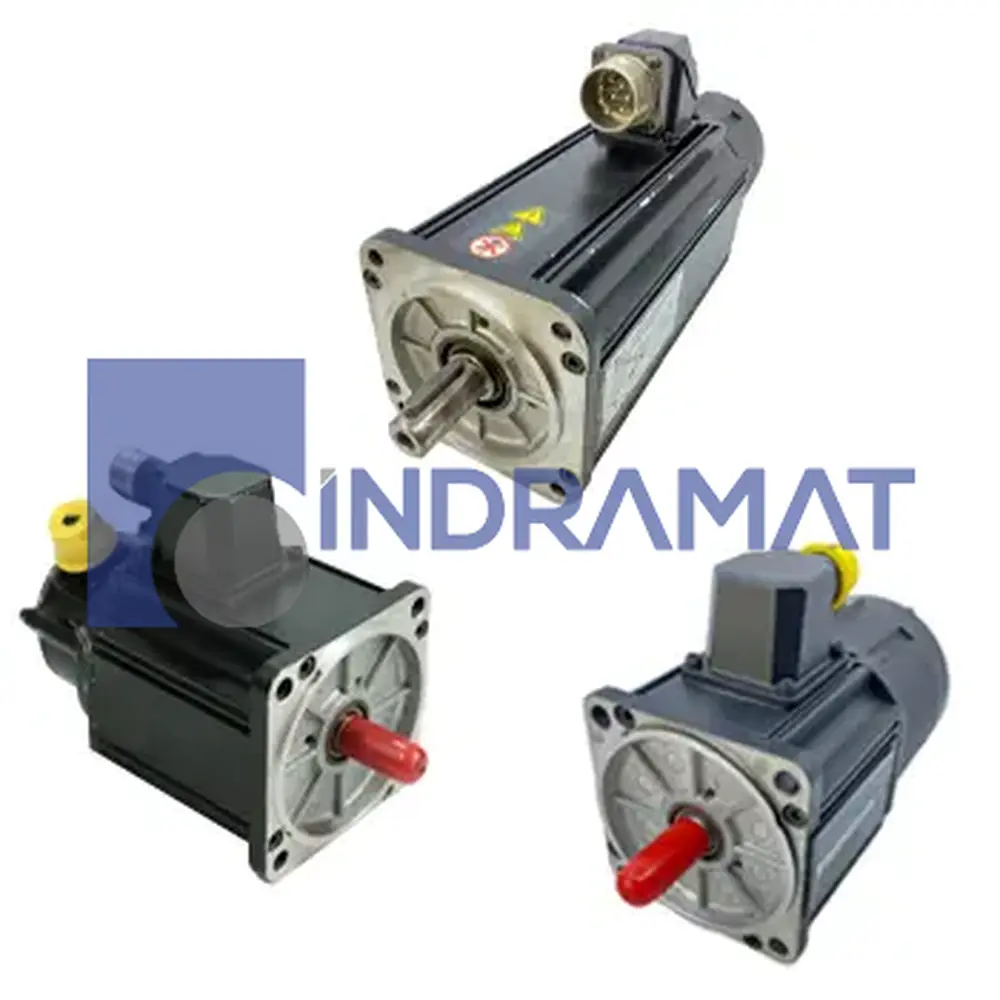
The Bosch Rexroth Indramat MDD025A-N-100-N2K-040ME0 from the MDD Synchronous Motors series by Bosch Rexroth Indramat is a precision-built digital drive motor for advanced automation applications. This model features a motor size 025 frame and a motor length code A to optimize space in compact machine designs. The unit delivers a continuous torque at standstill of 0.33 Nm with a rated nominal speed of 10000 min‒1, ensuring responsive performance across dynamic load changes. With a centering diameter of 40 mm and a standard housing, the motor ensures straightforward mechanical alignment and robust protection in industrial environments.
Engineered for straightforward integration, this motor includes an integrated absolute encoder paired with resolver feedback for accurate position control and rapid commissioning. The connection type is a factory-fitted connecting cable with coupling unit, oriented in a left connection direction to match common panel layouts. The design omits a holding brake and shaft seal to reduce maintenance points, while the shaft type keyway and shaft end standard (without side B shaft end) provide secure torque transmission and compatibility with a range of couplings. A standard balancing process lowers vibration at high speed, and the absence of a blocking brake reduces inertia for quick dynamic response.
Ideal for integration with Bosch Rexroth digital drive controllers, this motor for digital drive controllers offers seamless electronic nameplate loading and auto-parameterization. The compact footprint, coupled with robust feedback and precise torque output, makes the MDD025A-N-100-N2K-040ME0 an optimal choice for high-speed spindles, gantry systems, and indexing tables. Its straightforward configuration and proven Indramat reliability translate into reduced commissioning time and consistent, repeatable performance across diverse automation tasks.
Technical Specifications
Balancing
Standard
Holding Brake
Without blocking brake
Centering Diameter
40 mm
Housing
Standard
Encoder
Integrated absolute encoder
Motor Feedback
Resolver feedback
Continuous Torque at Standstill
0.33 Nm
Motor Length Code
A
Motor Size
025
Nominal Speed
10000 min⁻¹
Shaft Seal
Without shaft seal
Shaft Type
keyway
Connection Direction
Left
Connection Type
Connecting cable with coupling unit
Product Type
Motor for digital drive controllers
Shaft End
Standard (without side B shaft end)
Frequently Asked Questions
Why is continuous torque at standstill so low (≈ 0.33 Nm) compared to peak torque, and what does this imply in real applications?
Because holding torque depends mostly on the current available without cooling flow, and natural convection cooling limits continuous current substantially. In real systems, long-term static loads or millisecond holds must be sized with that low standstill torque in mind (e.g. external brakes may be required).
What are the thermal limitations of using natural convection cooling on this motor in high‐duty robotics or CNC use?
Natural convection limits heat dissipation especially when ambient is high or airflow is blocked; duty cycles with long high‐torque or high‐speed segments will increase winding temperature, reducing torque output or risking insulation damage. Forced cooling or pauses may be required in applications with ≥ 50% duty cycle or ambient above ~40 °C.
In what way does the nominal speed of 10 000 min⁻¹ influence selection of gearbox, bearing, and mechanical inertia matching?
At high speed, mechanical inertia of the driven load becomes more significant—if load inertia is too large, acceleration suffers and drive currents spike, increasing thermal stress. Also bearings must be rated for such speed; any added gearbox must be capable of transmitting torque at the full speed without introducing vibration or backlash that interferes with stability.
What maintenance or calibration risks do resolver feedback systems bring compared to only using incremental or simple encoders?
Resolvers are more rugged (tolerant to heat, dirt) but less precise unless properly calibrated; drift in phase, amplitude or signal distortions can introduce errors unless periodic calibration or signal verification is performed. Additionally, cabling for resolver must maintain shielding and minimal distortion to avoid noise affecting commutation.
How does the absence of a holding (blocking) brake (i.e. “without blocking brake”) impact safety and design in vertical or load-bearing applications?
Without a holding brake, the motor cannot prevent motion under load when power is removed—so for vertical axes, robot picks, etc., an external brake or mechanical lock is required to avoid drift or failure. It also means emergency stop scenarios need design provisions: dynamic braking circuits or physical restraints.
Common Misspellings
MDD-025A-N-100-N2K-040ME0
MDD025A N 100 N2K 040ME0
MDD025A-N-100-N2K-040-ME0
MDD025A-N-100-N2K-040-MEO
MDD025A-N-100-N2K-040MEO
MDD025AN100N2K040ME0
MDD25A-N-100-N2K-040ME0
MDDO25A-N-100-N2K-040ME0
MDDO25A-N-1OO-N2K-O4OMEO
Internal Product Review
The MDD025A-N-100-N2K-040ME0 from Bosch Rexroth Indramat is a synchronous servo motor with a 100 mm frame size, natural convection cooling, and N2K feedback. It delivers up to 40 Nm peak torque and uses a mechanical encoder for accuracy. This motor is commonly used in packaging, robotics, CNC machinery, and semiconductor applications.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MDD025A-N-100-N2K-040ME0.
 Want to