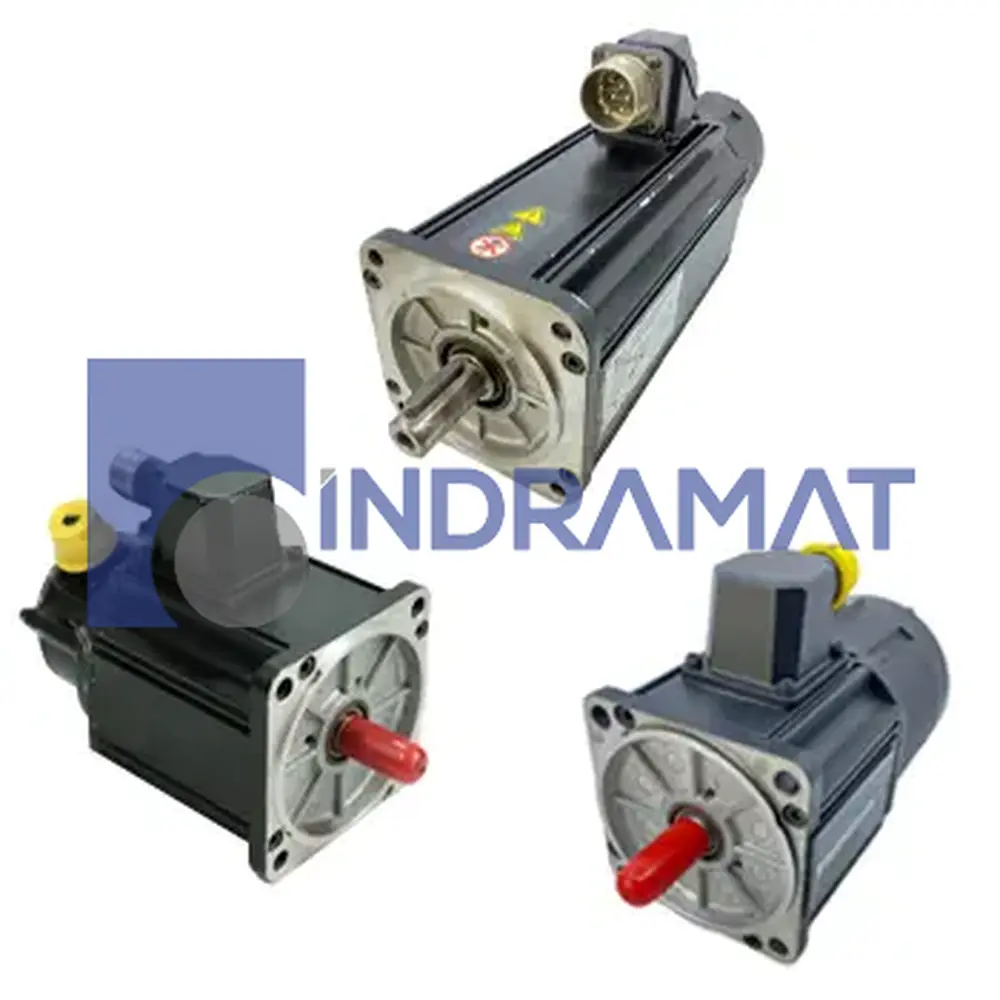
MDD025A-N-100-N2K-040PA1
MDD Synchronous Motors
Technical Specifications
Balancing
Standard
Holding Brake
With blocking brake
Holding Brake Torque
1.0 Nm
Centering Diameter
40 mm
Housing
Standard
Encoder
Integrated absolute encoder
Motor Feedback
Resolver feedback
Continuous Torque at Standstill
0.33 Nm
Motor Length Code
A
Motor Size
025
Nominal Speed
10000 min⁻¹
Shaft Seal
With shaft seal
Shaft Type
keyway
Connection Direction
Side A
Connection Type
Connector
Product Type
Motor for digital drive controllers
Shaft End
Standard (without side B shaft end)
Frequently Asked Questions
How does including both an absolute encoder and resolver feedback affect control system design?
Dual feedback gives redundancy and more precise absolute positioning (via encoder) plus robustness in harsh conditions (via resolver), but requires a drive or controller that can accept both kinds of signals and appropriately fuse them. It also increases wiring and possibly calibration complexity.
How does the 10,000 min⁻¹ nominal speed influence application choices?
At that high RPM, mechanical balancing, bearing quality, and thermal dissipation of the motor become critical; run-up and braking profiles must be designed so that inertia loads and gearbox couplings do not induce vibration or overshoot. Also, feedback devices must maintain accuracy at high shaft speeds without signal degradation.
What installation alignment and mounting constraints arise from the 40 mm centering diameter and keyway shaft?
The 40 mm centering diameter demands precision mounting surfaces and matching flanges to avoid misalignment that can lead to bearing wear or shaft run-out. The keyway ensures torque transmission, but key sizing, key fit and protection from shear must be considered, especially under reversal or high transient loads.
What is the impact of the 1.0 Nm holding (blocking) brake torque in safety or position holding applications?
The brake provides static holding beyond what (or when) the motor drive is unpowered; in safety design you still need to verify that 1.0 Nm is enough for the load moment and any external forces. Also the control logic must allow for the brake engagement/disengagement timing (delay, power, wear).
What are thermal considerations for continuous operation at standstill vs running at nominal speed?
When held at standstill (especially under load or with brake engaged), heat builds up without airflow cooling; running at nominal speed offers cooling via rotor/stator wind effects. So continuous torque at standstill must be derated or allowed duty cycles with cooling or intermittent use.
Common Misspellings
MDD-025A-N-100-N2K-040PA1
MDD025A N 100 N2K 040PA1
MDD025A-N-100-N2K-040-PA1
MDD025AN100N2K040PA1
MDD25A-N-100-N2K-040PA1
MDDO25A-N-100-N2K-040PA1
MDDO25A-N-1OO-N2K-O4OPA1
Internal Product Review
The MDD025A-N-100-N2K-040PA1 motor by Bosch Rexroth features an integrated absolute encoder, resolver feedback, and a blocking brake with 1.0 Nm torque. With 0.33 Nm continuous torque at standstill, 40 mm centering diameter, and 10,000 min⁻¹ nominal speed, it ensures precise operation. This motor supports automation needs in robotics, packaging, and semiconductor equipment.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MDD025A-N-100-N2K-040PA1.
 Want to