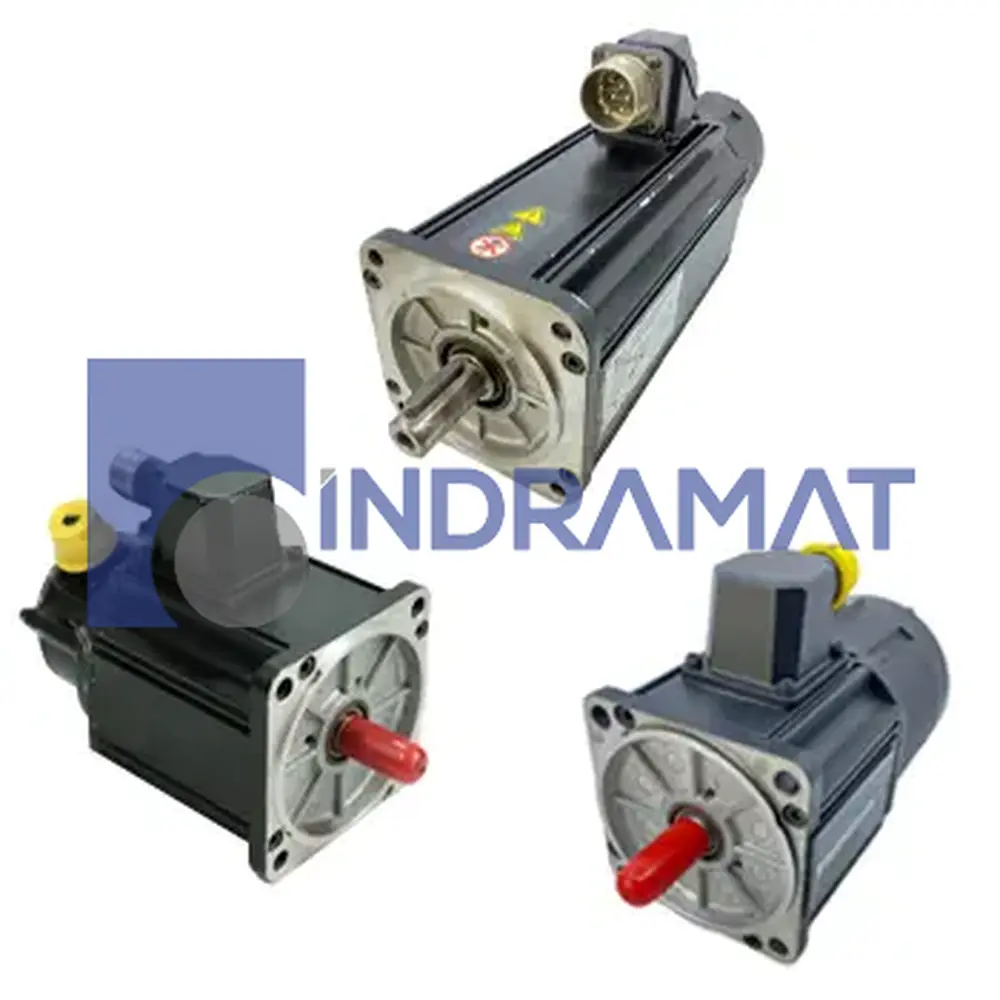
MDD025A-N-100-N2K-040PC1
MDD Synchronous Motors
Technical Specifications
Balancing
Standard
Holding Brake
With blocking brake
Holding Brake Torque
1.0 Nm
Centering Diameter
40 mm
Housing
Standard
Encoder
Integrated absolute encoder
Motor Feedback
Resolver feedback
Continuous Torque at Standstill
0.33 Nm
Motor Length Code
A
Motor Size
025
Nominal Speed
10000 min⁻¹
Shaft Seal
With shaft seal
Shaft Type
keyway
Connection Direction
Side A
Connection Type
Connecting cable with coupling unit
Product Type
Motor for digital drive controllers
Shaft End
Standard (without side B shaft end)
Frequently Asked Questions
What installation alignment challenges arise from the 40 mm centering diameter and keyway shaft?
The 40 mm centering diameter presumes mating hardware and mounts that match that spindle for concentricity; misalignment can cause vibration or bearing wear. The keyway shaft simplifies torque transmission to couplings or gears but requires the correct key and tolerances per standard (e.g. DIN keyway), and care in mounting to avoid keyway stress concentrations.
What are the electrical and mechanical connection considerations of the “connecting cable with coupling unit, side-A connection”?
The side-A connection implies the cable exits on the designated side (matching drive/mounting layout), so the cable routing and space constraints must consider bend radius, drag chains, etc. The coupling unit needs proper mating connectors and possible shielding if used in electrically noisy environments; connector type and pin-outs must match the drive’s requirements.
What vibration and balancing considerations come with “standard balancing”?
Standard balancing typically means the rotor is balanced sufficiently for most applications but may not meet requirements for ultra-high speed, extremely low vibration, or precision optics/semiconductor handling. For those, “high precision” or “high balancing grade” versions might be needed to reduce runout and micro-vibrations.
How will using the MDD025A-N-100-N2K-040PC1 impact drive compatibility and controller demands?
Because this motor is designed for digital drive controllers and provides resolver + absolute encoder feedback, the drive must support those feedback types, have sufficient current capacity, and be able to handle the thermal and dynamic requirements (peak currents, braking regen, inertia). Controller firmware must also support the encoder protocols, possibly calibration (offset, scaling), and safety features tied to the holding brake.
What are the practical implications of using the 1.0 Nm holding (blocking) brake in this motor?
The 1.0 Nm brake allows the rotor to stay locked under small torques when de-energized, which is useful for safety or position hold, but it adds inertia and requires extra torque from the motor during braking/unbraking cycles. Also the brake consumes power (for example to release) and may produce heat, so thermal load and control wiring need to be planned accordingly.
Common Misspellings
MDD-025A-N-100-N2K-040PC1
MDD025A N 100 N2K 040PC1
MDD025A-N-100-N2K-040-PC1
MDD025AN100N2K040PC1
MDD25A-N-100-N2K-040PC1
MDDO25A-N-100-N2K-040PC1
MDDO25A-N-1OO-N2K-O4OPC1
Internal Product Review
The MDD025A-N-100-N2K-040PC1 motor by Bosch Rexroth offers resolver feedback, 0.33 Nm continuous torque, and a 10,000 min⁻¹ nominal speed. It includes a 1.0 Nm holding brake, shaft seal, and side-A connection with keyway shaft type. This motor suits precision roles in robotics, medical devices, and semiconductor machinery.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MDD025A-N-100-N2K-040PC1.
 Want to