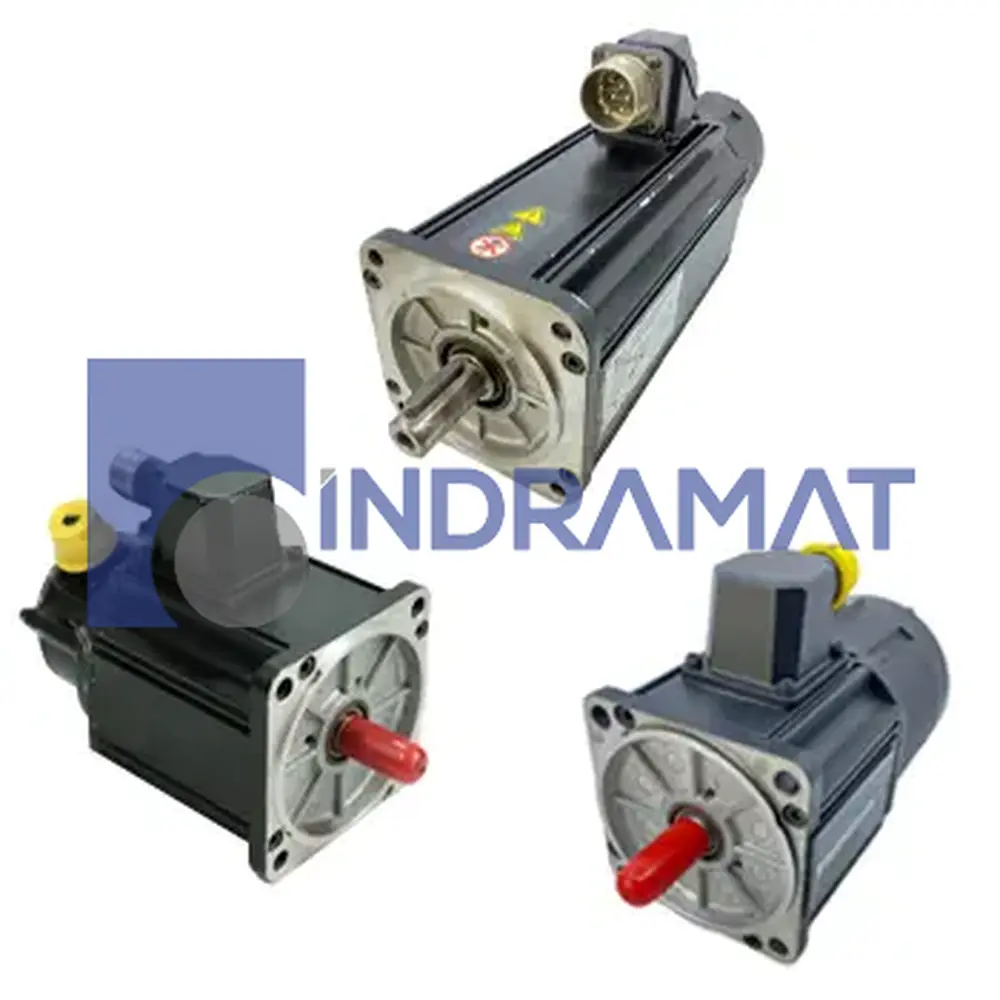
MDD025A-N-100-N2K-040PE1
MDD Synchronous Motors
Technical Specifications
Balancing
Standard
Holding Brake
With blocking brake
Holding Brake Torque
1.0 Nm
Centering Diameter
40 mm
Housing
Standard
Encoder
Integrated absolute encoder
Motor Feedback
Resolver feedback
Continuous Torque at Standstill
0.33 Nm
Motor Length Code
A
Motor Size
025
Nominal Speed
10000 min⁻¹
Shaft Seal
With shaft seal
Shaft Type
keyway
Connection Direction
Left
Connection Type
Connecting cable with coupling unit
Product Type
Motor for digital drive controllers
Shaft End
Standard (without side B shaft end)
Frequently Asked Questions
How large or heavy is the shaft end load the holding brake (1.0 Nm) can support in the MDD025A-N-100-N2K-040PE1?
The holding brake torque of 1.0 Nm indicates how much resisting torque is available when power is cut; it’s suitable for small to moderate loads to prevent motion from gravity or inertia. But for large vertical axes or heavy tooling, this brake will likely need mechanical locks or additional brakes to safely hold loads.
What does the “40 mm centering diameter” mean in terms of mounting and coupling alignment?
The centering diameter defines the diameter of the flange or the locating surface used for mechanical alignment, helping ensure coaxial mounting and minimizing runout. Using the correct centering diameter means better dynamic performance and reduced bearing loads due to misalignment.
How would connection direction (“Left”) and cable with coupling unit affect installation flexibility and cable routing?
Left-side connection means the cable exit is fixed; this must be considered in machine layout and routing to avoid stress on cable or coupling unit, potentially leading to failures. Using a coupling unit mitigates strain at the motor flange, but space for the cable bend radius must still be planned.
What are the trade-offs of using a blocking brake of 1.0 Nm on this motor in terms of inertia and braking speed?
The brake adds mechanical components that contribute to rotor inertia, slowing down acceleration and deceleration slightly, and may require more drive current or torque margin during dynamic start/stop cycles. Also, brake actuation time and wear must be considered in high-cycle applications, and safe disengagement under load must be verified.
What system requirements or drive features must be in place to use the MDD025A-N-100-N2K-040PE1 properly (feedback interface, commutation, safety)?
The drive/controller must support both resolver feedback (analog sine/cosine) and absolute encoder signals, plus proper signal conditioning or A/D conversion for the resolver, and must handle calibration/homing routines if needed. Safety functions should include brake control (power cutoff and holding brake), over-speed protection (given 10,000 min⁻¹), and thermal monitoring, since continuous high speed can generate heat.
Common Misspellings
MDD-025A-N-100-N2K-040PE1
MDD025A N 100 N2K 040PE1
MDD025A-N-100-N2K-040-PE1
MDD025AN100N2K040PE1
MDD25A-N-100-N2K-040PE1
MDDO25A-N-100-N2K-040PE1
MDDO25A-N-1OO-N2K-O4OPE1
Internal Product Review
The MDD025A-N-100-N2K-040PE1 is a digital AC servo motor by Bosch Rexroth Indramat. It features a nominal speed of 10,000 min⁻¹ and an integrated absolute encoder for precise control, with a 1.0 Nm holding brake. This motor is ideal for applications in automation, robotics, and CNC machinery, offering reliable performance and easy integration.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MDD025A-N-100-N2K-040PE1.
 Want to