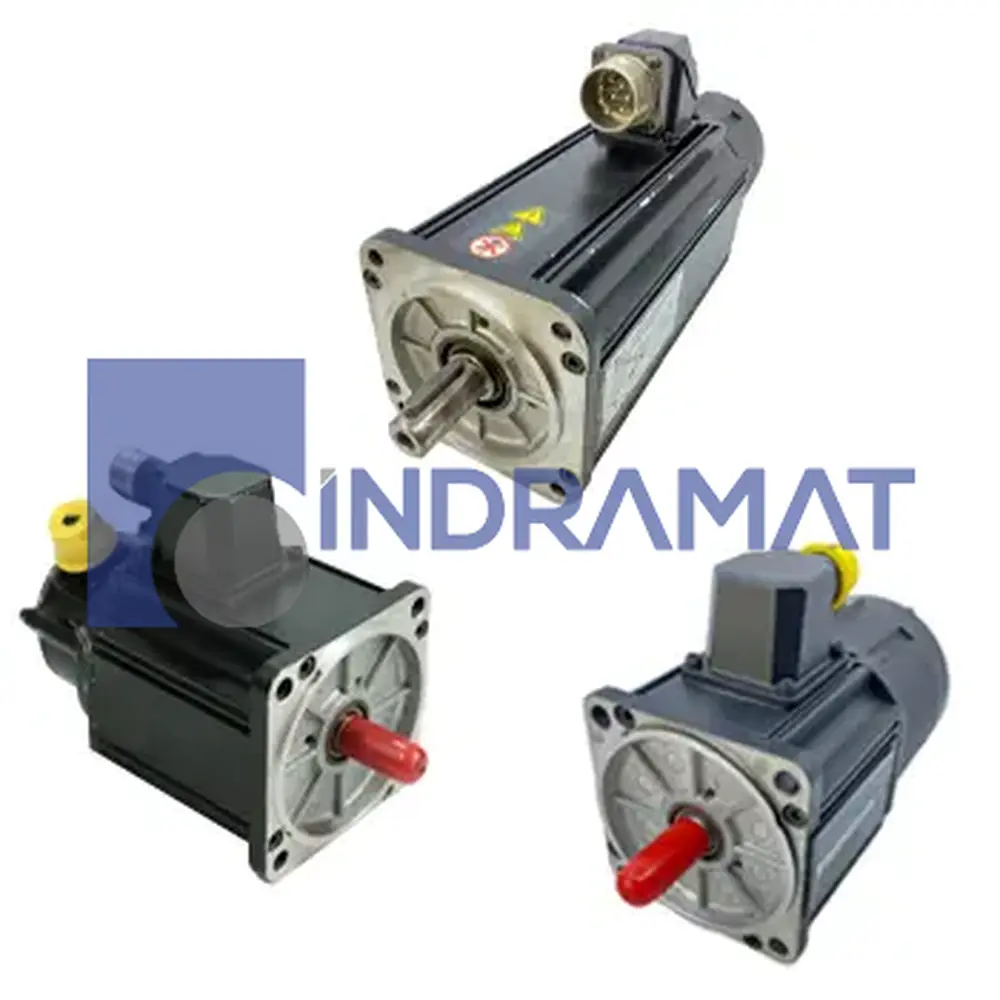
MDD025A-N-100-N2K-040PF1
MDD Synchronous Motors
Technical Specifications
Balancing
Standard
Holding Brake
With blocking brake
Holding Brake Torque
1.0 Nm
Centering Diameter
40 mm
Housing
Standard
Encoder
Integrated absolute encoder
Motor Feedback
Resolver feedback
Continuous Torque at Standstill
0.33 Nm
Motor Length Code
A
Motor Size
025
Nominal Speed
10000 min⁻¹
Shaft Seal
With shaft seal
Shaft Type
keyway
Connection Direction
Right
Connection Type
Connecting cable with coupling unit
Product Type
Motor for digital drive controllers
Shaft End
Standard (without side B shaft end)
Frequently Asked Questions
What mechanical alignment or mounting considerations are dictated by the 40 mm centering diameter?
The centering diameter must match the mating flange to avoid misalignment; any mismatch leads to shaft offset that causes vibration, bearing wear, or reduced encoder accuracy. It also dictates the minimal size of couplings and adapters used
How should one account for shaft loading (radial and axial) given the shaft type (keyway) and presence of shaft seal?
The keyway accommodates torque transmission but may reduce shaft cross-section, so radial loads on the shaft must be kept below what the bearings can handle, especially close to the shaft end. The shaft seal helps protect bearings from contamination or lubricant loss, but sealing adds friction and can affect temperature rise slightly.
What maintenance or reliability issues are associated with the integrated absolute encoder for long-term industrial use?
Dust, vibration, and thermal cycling can degrade encoder accuracy or damage optics/electronics; ensuring proper sealing, vibration isolation, and phased calibration checks helps preserve precision. Also, absolute encoders often have more complex wiring and diagnostics—ensure the control system supports error detection and re-initialization.
How would using this motor (Bosch Rexroth Indramat MDD025A-N-100-N2K-040PF1) influence the design of control loop bandwidth and servo tuning in CNC or robotics?
Because it has high nominal speed, high feedback resolution (resolver + encoder), and relatively small torque, the system can be tuned for faster response but may hit limits in torque output at higher speeds. You’ll need to carefully tune proportional/integral gains to avoid overshoot, especially near speed transitions or when moving heavy loads with low torque margin.
What advantage or drawback does the right-hand cable/coupling orientation pose in compact machine layouts?
Right-hand routing may simplify cabling in some setups but can interfere or limit flexibility in others—routing strain, bend radius, or clearance around adjacent components can be restricted. Ensuring sufficient slack and using proper coupling units helps prevent mechanical fatigue and connector damage.
Common Misspellings
MDD-025A-N-100-N2K-040PF1
MDD025A N 100 N2K 040PF1
MDD025A-N-100-N2K-040-PF1
MDD025AN100N2K040PF1
MDD25A-N-100-N2K-040PF1
MDDO25A-N-100-N2K-040PF1
MDDO25A-N-1OO-N2K-O4OPF1
Internal Product Review
The Bosch Rexroth Indramat MDD025A-N-100-N2K-040PF1 is a digital AC servo motor with a nominal speed of 10,000 min⁻¹ and a continuous standstill torque of 0.33 Nm. It features an integrated absolute encoder and resolver feedback for precise motor control. This motor is ideal for applications in robotics, CNC machinery, and automated manufacturing systems.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MDD025A-N-100-N2K-040PF1.
 Want to