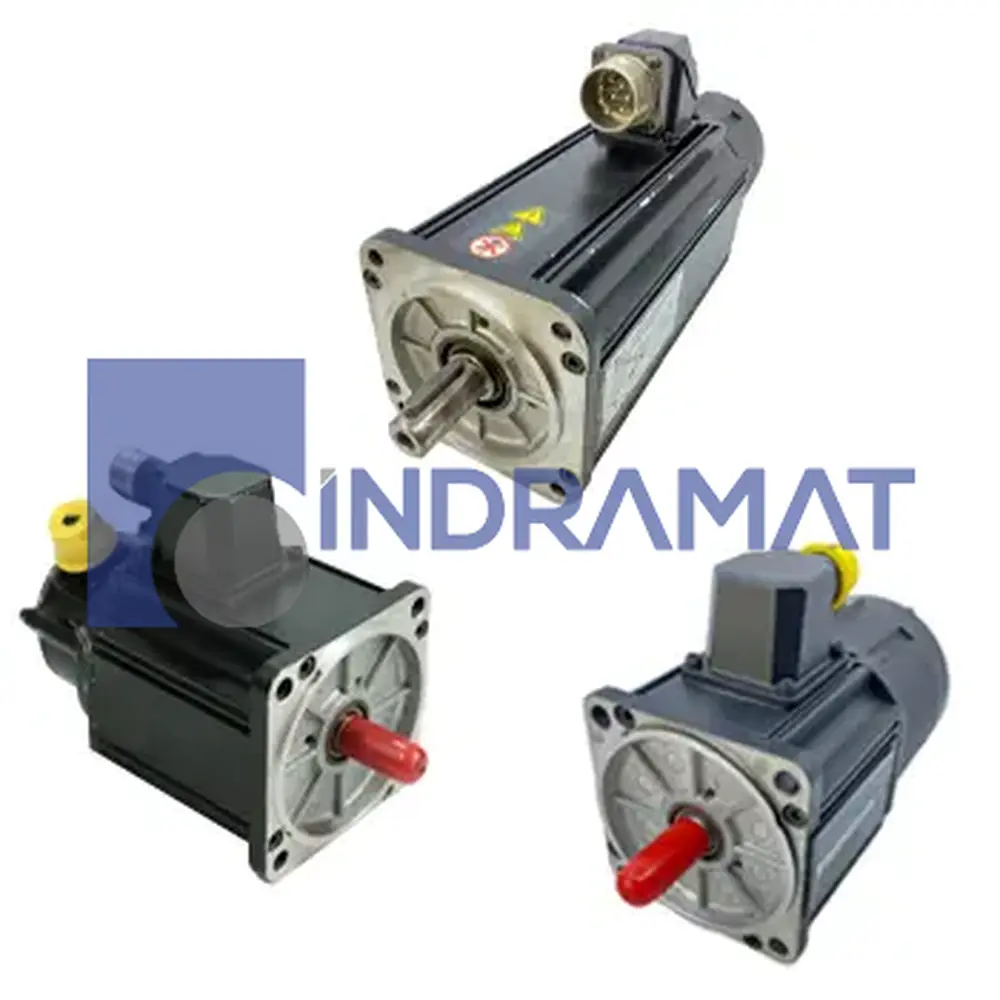
MDD090A-N-030-N2L-110GR0
MDD Synchronous Motors
Technical Specifications
Balancing
Standard
Holding Brake
Without blocking brake
Centering Diameter
110 mm
Housing
Standard
Motor Feedback
Digital servo feedback (DSF)
Continuous Torque at Standstill
3.7 Nm
Motor Length Code
A
Motor Size
090
Nominal Speed
3000 min⁻¹
Shaft Seal
With shaft seal
Shaft Type
Plain shaft
Connection Direction
Right
Connection Type
Connector
Product Type
Motor for digital drive controllers
Shaft End
Standard (without side B shaft end)
Frequently Asked Questions
What installation clearances and flange alignment tolerances should be used when mounting the Bosch Rexroth Indramat MDD090A-N-030-N2L-110GR0?
Keep the motor’s 110 mm centering diameter concentric to mating parts and limit runout to the small-millimeter range to avoid extra bearing loads; use a soft-start alignment procedure to prevent shock loads during first commissioning. Proper concentric mounting reduces vibration and extends bearing/encoder life.
How does a continuous standstill torque of ~3.7 Nm affect duty-cycle planning and thermal design for this motor?
A 3.7 Nm continuous torque at standstill implies the motor can hold moderate loads without rotation but will generate steady heat that must be accounted for in ambient-temperature and cooling budgets; use the motor’s thermal time constant and rated ambient to size ventilation or cooling. This rating guides selection of servo tuning and intermittent torque margins to avoid thermal trips.
What are the service and maintenance implications of a sealed housing with a shaft seal on this motor?
A shaft seal protects internal bearings and electronics from contaminants and allows use in slightly harsher environments, but it also means periodic inspection of the external seal and bearing temperatures is required since seals can hide progressive wear. Plan bearing-temperature trending and vibration checks rather than relying on visual inspection alone.
How should one evaluate rotor inertia and gearbox selection when integrating this 090-size motor into a robotic joint?
Calculate the reflected load inertia at the motor shaft and keep the ratio (J_load / J_motor) ideally close to 1–10 depending on control aggressiveness; if the ratio is high, use a reduction gearbox to lower effective inertia or accept slower closed-loop bandwidth and more conservative servo gains. Consider backlash and torsional stiffness of the gearbox as they directly affect position stability and contouring performance.
What spare parts and B2B lifecycle considerations should a purchaser of the Bosch Rexroth Indramat MDD090A-N-030-N2L-110GR0 plan for in a production line?
Stock critical spares such as a replacement encoder/feedback module, bearing set, and an identical motor to avoid long downtime; additionally, verify repair/return policies and lead times from authorized distributors because legacy Indramat MDD parts can have varying availability.
Common Misspellings
MDD-090A-N-030-N2L-110GR0
MDD090A N 030 N2L 110GR0
MDD090A-N-030-N2L-110-GR0
MDD090A-N-030-N2L-110-GRO
MDD090A-N-030-N2L-110GRO
MDD090AN030N2L110GR0
MDD90A-N-030-N2L-110GR0
MDDO90A-N-030-N2L-110GR0
MDDO9OA-N-O3O-N2L-11OGRO
Internal Product Review
The MDD090A-N-030-N2L-110GR0 motor by Bosch Rexroth is a digital servo motor with 3.7 Nm continuous torque at 3000 rpm. It features a plain shaft, right-side connector, and 110 mm centering diameter. This motor is commonly used in robotics, textile machinery, and automated packaging systems.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MDD090A-N-030-N2L-110GR0.
 Want to