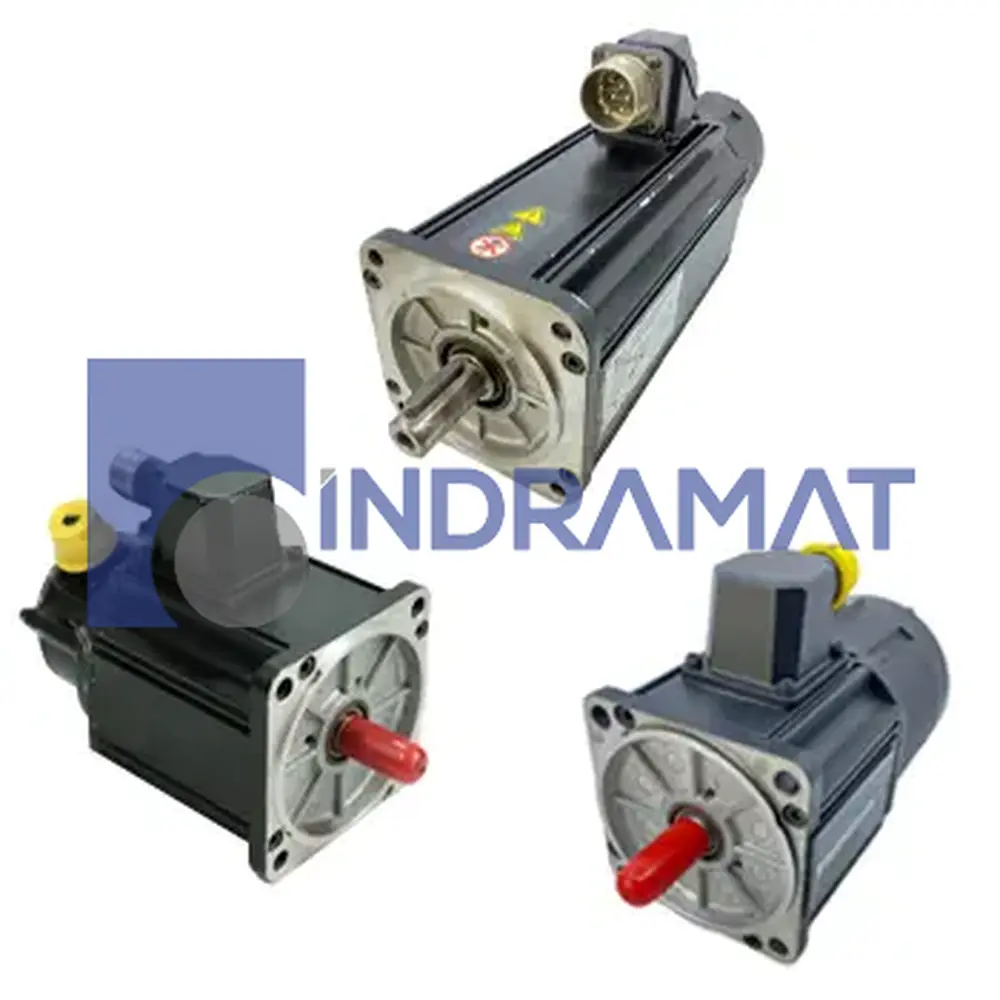
MDD090C-N-030-N2L-130PR2
MDD Synchronous Motors
Technical Specifications
Balancing
Standard
Holding Brake
With blocking brake
Holding Brake Torque
11.0 Nm
Centering Diameter
130 mm
Housing
Standard
Motor Feedback
Digital servo feedback (DSF)
Continuous Torque at Standstill
10.4 Nm
Motor Length Code
C
Motor Size
090
Nominal Speed
3000 min⁻¹
Shaft Seal
With shaft seal
Shaft Type
keyway
Connection Direction
Right
Connection Type
Connector
Product Type
Motor for digital drive controllers
Shaft End
Standard (without side B shaft end)
Frequently Asked Questions
What are the structural implications of a 130 mm centering diameter in mounting interfaces?
This relatively large centering diameter gives you good stiffness and repeatability when mating to machine frames or flanges, but it also means the mounting structure or hub must precisely conform to that diameter to avoid misalignment. In retrofit designs, you must check clearances and tolerances tightly to avoid interference or runout.
What must be considered when using the 11.0 Nm holding brake during intermittent stops?
The brake must be energized or de-energized in sync with motion commands, and it should be dimensioned so that its friction torque dominates peak loads during standstill. Ensure the brake’s power supply and blending with servo current don’t introduce step-change torque transients.
How does having a keyway shaft rather than a smooth shaft affect coupling design?
A keyway gives you positive torque transmission without slippage, but you must ensure the key and key seat tolerances are tight and that the shaft shoulder supports axial loads. Also consider stress concentrations around the keyway when computing fatigue loads in cyclic operations.
What cooling and thermal limits should be observed in continuous operation?
Even though it may run “cooled by ambient convection,” sustained loads near its limits will raise stator winding temperature—so maintain ambient limits and allow for ventilation. If your duty cycle needs continuous high torque, adding forced-air or liquid cooling may extend performance headroom.
How should you size the drive current limits and safety margins around the holding brake when commanded motion reversals occur?
In a reversal, torque demand may transiently exceed steady-state values, so your drive current limit needs headroom (e.g. 1.5–2× peak) and your brake engagement timing needs to avoid fighting the servo moment. Also allow for safety interlocks to prevent the brake from engaging while the motor is driving.
Common Misspellings
MDD-090C-N-030-N2L-130PR2
MDD090C N 030 N2L 130PR2
MDD090C-N-030-N2L-130-PR2
MDD090CN030N2L130PR2
MDD90C-N-030-N2L-130PR2
MDDO90C-N-030-N2L-130PR2
MDDO9OC-N-O3O-N2L-13OPR2
Internal Product Review
The MDD090C-N-030-N2L-130PR2 motor by Bosch Rexroth offers 10.4 Nm continuous standstill torque and a nominal speed of 3000 min⁻¹. It includes a 130 mm centering diameter, keyway shaft, and 11.0 Nm holding brake, with digital servo feedback. This motor suits CNC machines, printing systems, and industrial automation setups.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MDD090C-N-030-N2L-130PR2.
 Want to