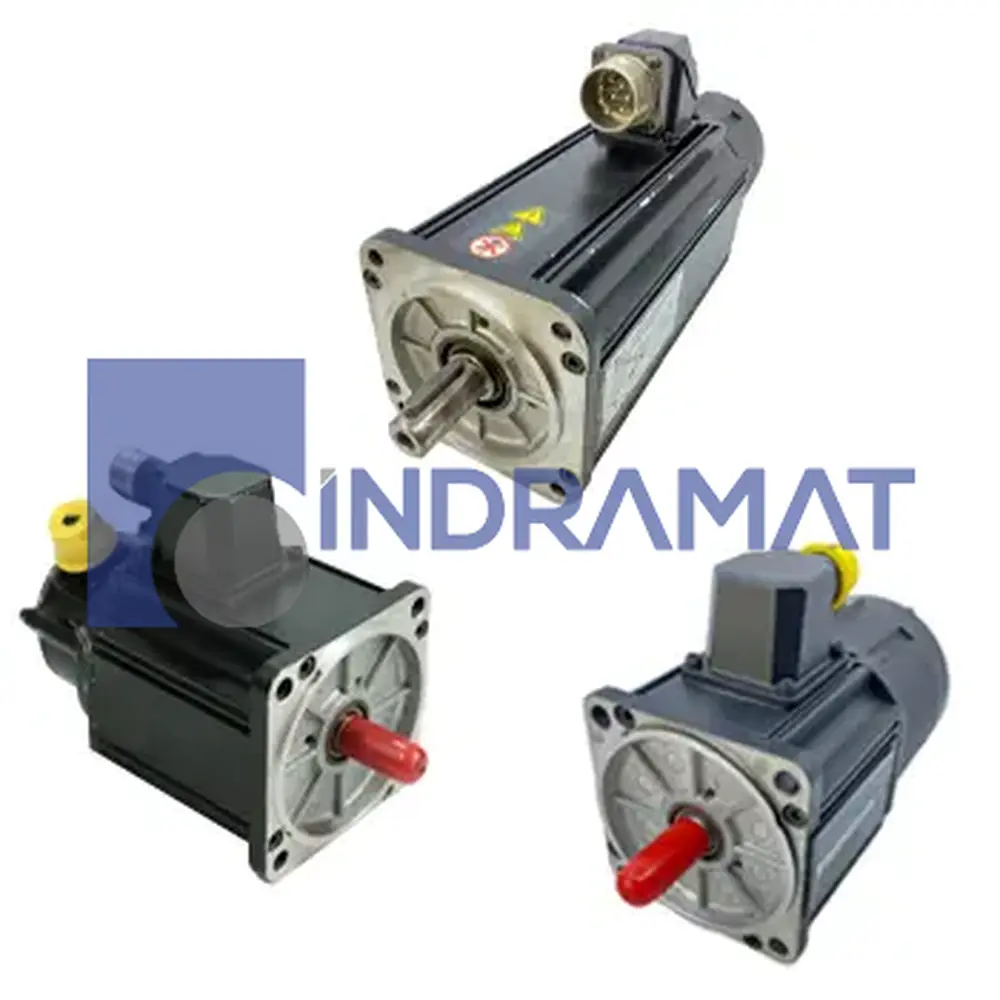
MDD093D-N-040-N2L-110GL0
MDD Synchronous Motors
Technical Specifications
Balancing
Standard
Holding Brake
Without blocking brake
Centering Diameter
110 mm
Housing
Standard
Motor Feedback
Digital servo feedback (DSF)
Continuous Torque at Standstill
24.0 Nm
Motor Length Code
D
Motor Size
093
Nominal Speed
4000 min⁻¹
Shaft Seal
With shaft seal
Shaft Type
Plain shaft
Connection Direction
Left
Connection Type
Connector
Product Type
Motor for digital drive controllers
Shaft End
Standard (without side B shaft end)
Frequently Asked Questions
In what scenarios would the absence of a blocking (holding) brake limit the use of this motor?
Without a holding brake, it cannot reliably resist external torque when power is off—so it’s unsuitable for vertical axes or applications needing passive hold during power loss. It must always be in a driven, actively controlled state or backed by a mechanical lock.
How does the 24 Nm continuous torque at standstill translate to dynamic torque at higher speeds, e.g. at 4000 min⁻¹?
As speed increases, voltage and current limits typically reduce available torque; the motor’s torque curve will decline. The system’s drive must ensure enough voltage headroom and current margin to sustain useful torque at target speeds.
What are the thermal constraints and cooling considerations for running this motor continuously near 4000 rpm?
Heat must dissipate through the housing and shaft seal; adequate ambient cooling or forced ventilation is needed to keep winding temps under limits. Thermal time constants and insulation class determine how long it can endure peaks before overheating.
How would shaft seal usage influence lubricant retention and environmental resistance under harsh conditions?
A shaft seal helps retain bearing lubrication and protects internal components from ingress of coolant, dust, or oil mist. But under heavy side loads or shaft misalignment, the seal may wear faster and require maintenance planning.
How critical is matching the motor’s electrical interface (left-side connector) when integrating into a CNC or robot control architecture?
The left-side connector orientation establishes cable routing constraints; mis-oriented connectors may complicate harness routing or force extra bends, increasing EMI risk. You must ensure the servo drive interface, cable assembly, and protection outer conduit align with that orientation.
Common Misspellings
MDD-093D-N-040-N2L-110GL0
MDD093D N 040 N2L 110GL0
MDD093D-N-040-N2L-110-GL0
MDD093D-N-040-N2L-110-GLO
MDD093D-N-040-N2L-110GLO
MDD093DN040N2L110GL0
MDD93D-N-040-N2L-110GL0
MDDO93D-N-040-N2L-110GL0
MDDO93D-N-O4O-N2L-11OGLO
Internal Product Review
The MDD093D-N-040-N2L-110GL0 motor by Bosch Rexroth is built for digital drive controllers and includes a plain shaft, shaft seal, and left-side connector. It runs at 4000 RPM nominal speed with 24.0 Nm continuous torque and uses digital servo feedback. This motor is commonly used in robotics, CNC machinery, and packaging equipment.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MDD093D-N-040-N2L-110GL0.
 Want to