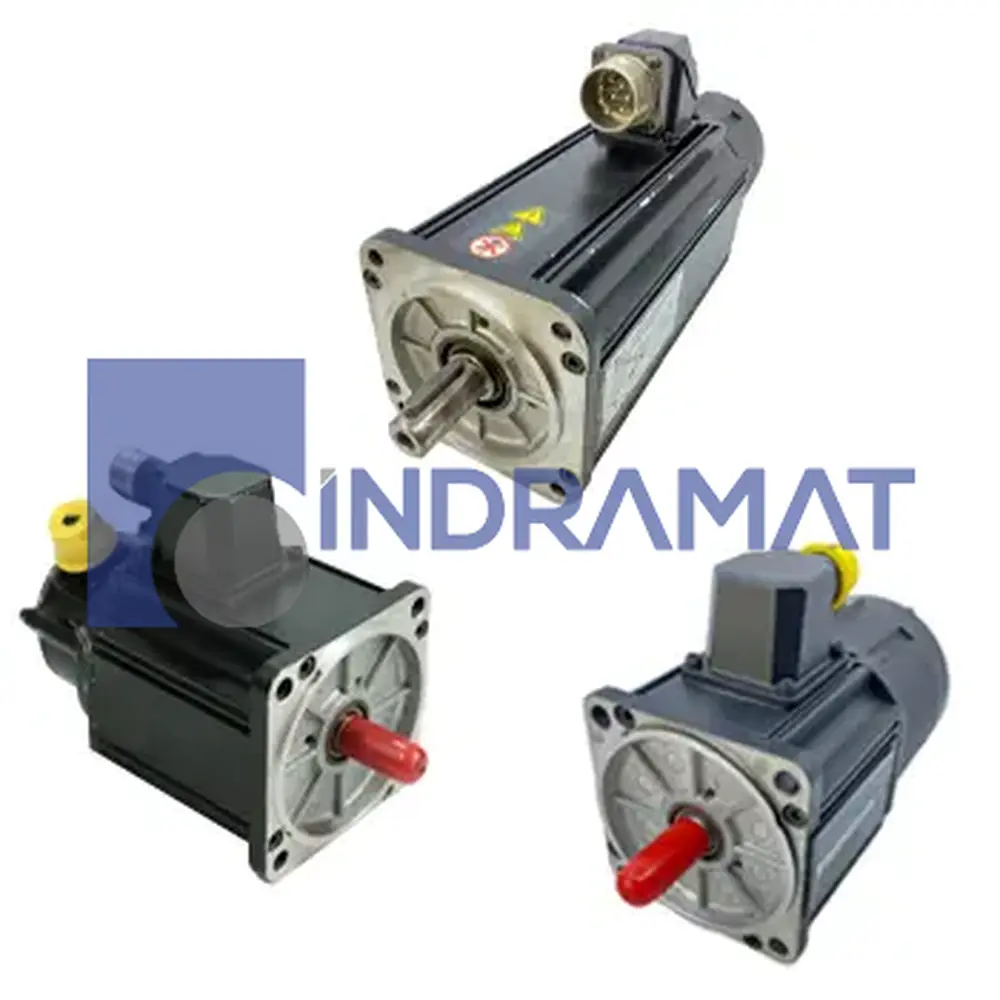
MDD093D-N-040-N2L-130GR0
MDD Synchronous Motors
Technical Specifications
Balancing
Standard
Holding Brake
Without blocking brake
Centering Diameter
130 mm
Housing
Standard
Motor Feedback
Digital servo feedback (DSF)
Continuous Torque at Standstill
24.0 Nm
Motor Length Code
D
Motor Size
093
Nominal Speed
4000 min⁻¹
Shaft Seal
With shaft seal
Shaft Type
Plain shaft
Connection Direction
Right
Connection Type
Connector
Product Type
Motor for digital drive controllers
Shaft End
Standard (without side B shaft end)
Frequently Asked Questions
What kind of current ripple or torque pulsation can I expect at 4000 min⁻¹ with this motor?
Due to synchronous operation with digital servo feedback, current ripple and torque ripple are minimized as the controller compensates for harmonics; residual ripple depends mostly on drive resolution and filter bandwidth. In practice, high-quality digital drives keep torque ripple below a few percent of nominal torque.
How does the 130 mm centering diameter affect mounting stiffness and alignment tolerance?
A larger centering diameter raises the bending stiffness of the coupling interface and reduces sensitivity to misalignment; you can tolerate slightly higher radial and angular offset without inducing excessive bearing loads. It also improves load distribution across the bearing housing and helps with dynamic stability at high shaft speeds.
How should I size the cable and connector given its nominal speed and digital servo feedback?
Because digital servo feedback demands low-latency and low-noise signals, use shielded twisted-pair or shielded multi-pair cables per Rexroth guidelines, and size power conductors so that voltage drop is <5 % at peak current. Keep cable runs short and route power and feedback separately to minimize EMI coupling.
Which dynamic loads (axial, radial, or torsional) should I particularly limit in a CNC or robotic application using this motor?
The motor bearings are typically optimized for radial loads; axial loads should be kept minimal (e.g. via thrust bearings or external supports) to avoid degrading bearing life. Torsional loads beyond the rated torque could lead to rotor demagnetization or stress in the shaft—so avoid torque spikes beyond ~1.5–2× continuous during acceleration.
What is the effect of ambient temperature or altitude on performance and cooling?
In high ambient temperatures or elevated altitudes (lower air density), natural convection cooling is less effective, which will reduce continuous torque capability before reaching thermal limits. For such environments, forced-air or external cooling may be required to maintain performance.
Common Misspellings
MDD-093D-N-040-N2L-130GR0
MDD093D N 040 N2L 130GR0
MDD093D-N-040-N2L-130-GR0
MDD093D-N-040-N2L-130-GRO
MDD093D-N-040-N2L-130GRO
MDD093DN040N2L130GR0
MDD93D-N-040-N2L-130GR0
MDDO93D-N-040-N2L-130GR0
MDDO93D-N-O4O-N2L-13OGRO
Internal Product Review
The MDD093D-N-040-N2L-130GR0 motor from Bosch Rexroth comes with a plain shaft, 130 mm centering diameter, and digital servo feedback. It delivers 24.0 Nm torque at standstill and runs at 4000 min⁻¹ nominal speed. This motor is used in CNC machinery, packaging lines, and robotic systems.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MDD093D-N-040-N2L-130GR0.
 Want to