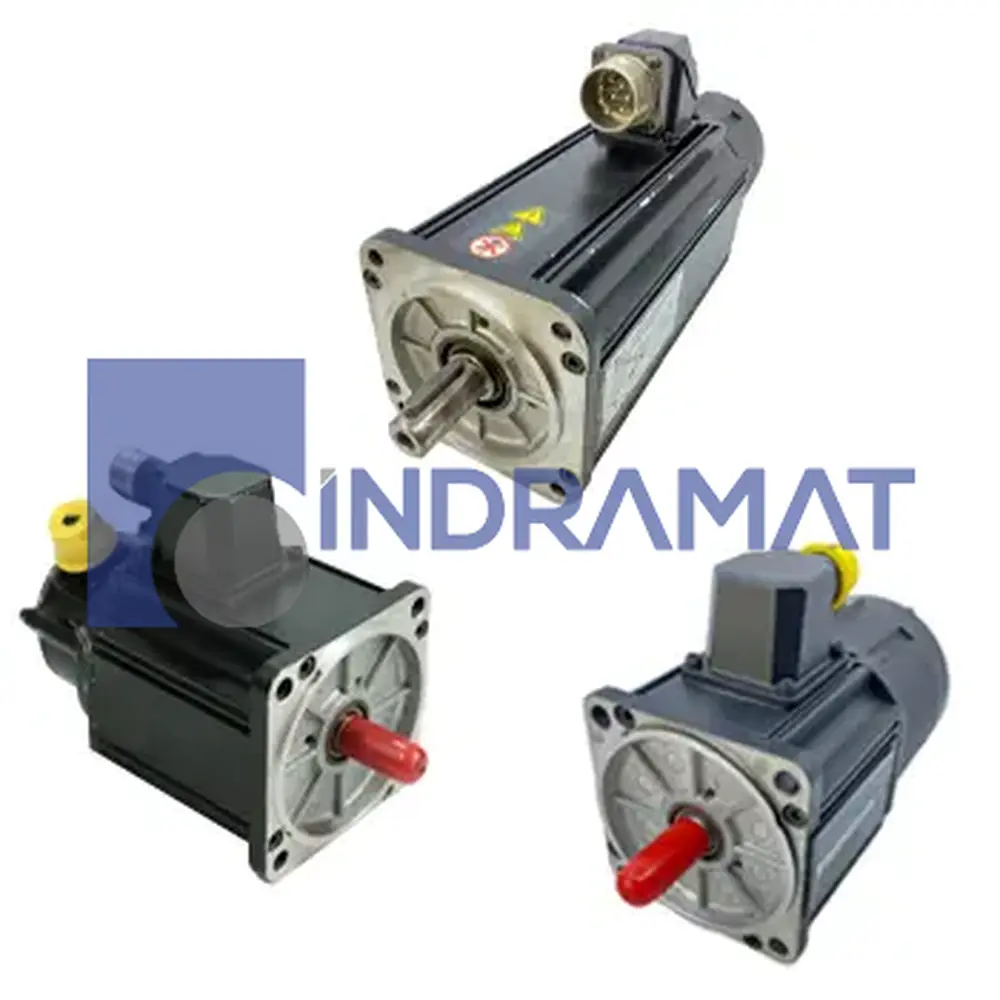
MDD093D-N-040-N2M-110GA0
MDD Synchronous Motors
Technical Specifications
Balancing
Standard
Holding Brake
Without blocking brake
Centering Diameter
110 mm
Housing
Standard
Encoder
Integrated multiturn absolute encoder
Motor feedback
Digital servo feedback (DSF)
Continuous Torque at Standstill
24.0 Nm
Motor Length Code
D
Motor Size
093
Nominal Speed
4000 min⁻¹
Shaft Seal
With shaft seal
Shaft Type
Plain shaft
Connection Direction
Side A
Connection Type
Connector
Product Type
Motor for digital drive controllers
Shaft End
Standard (without side B shaft end)
Frequently Asked Questions
How does “plain shaft” versus keyed shaft change coupling design?
A plain shaft often implies a smooth cylindrical interface, sometimes with shrink fit or clamping coupling designs; keyways may not be present, so coupling must accommodate friction or clamping torque without slippage. You must check whether your coupling design can reliably transmit torque under dynamic load without a key.
What considerations apply for using this motor in robotics or CNC synchronized axes?
Low inertia and high encoder resolution allow tight velocity and position loops for coordinated moves, but you must size drive current reserve for transient accelerations. Cable routing, EMC shielding, and drive tuning (e.g. decoupling cross-axis resonance) are critical in multi-axis systems.
How will the motor’s thermal performance change under continuous torque near stall?
Operating near standstill torque causes high I²R losses and local heating; thermal design (cooling, heat sinking, ambient conditions) becomes crucial to avoid winding insulation stress. The drive/feedback must monitor temperature sensors integrated into the motor (as per MDD series documentation) to prevent overheating
What effect does digital servo feedback (DSF) with multiturn absolute encoder bring in a power-off cycle?
Because of the multiturn absolute encoder, the motor/drive retains the absolute rotor position across power cycles (no rehoming). This enables faster restarts and zero referencing without external encoders or resync routines.
What determines the usable speed range before commutation error increases?
The quality and resolution of the integrated multiturn absolute encoder (DSF) and the current control bandwidth set the maximum reliable speed before angular error grows significantly. At high rpm the feedback latency and rotor inertia may dominate the control error.
Common Misspellings
MDD-093D-N-040-N2M-110GA0
MDD093D N 040 N2M 110GA0
MDD093D-N-040-N2M-110-GA0
MDD093D-N-040-N2M-110-GAO
MDD093D-N-040-N2M-110GAO
MDD093DN040N2M110GA0
MDD93D-N-040-N2M-110GA0
MDDO93D-N-040-N2M-110GA0
MDDO93D-N-O4O-N2M-11OGAO
Internal Product Review
The MDD093D-N-040-N2M-110GA0 motor by Bosch Rexroth delivers 24.0 Nm continuous torque at standstill and operates at a nominal speed of 4000 min⁻¹. It features a plain shaft, multiturn absolute encoder, and digital servo feedback with a 110 mm centering diameter. This motor is ideal for use in robotics, CNC machines, and packaging automation.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MDD093D-N-040-N2M-110GA0.
 Want to