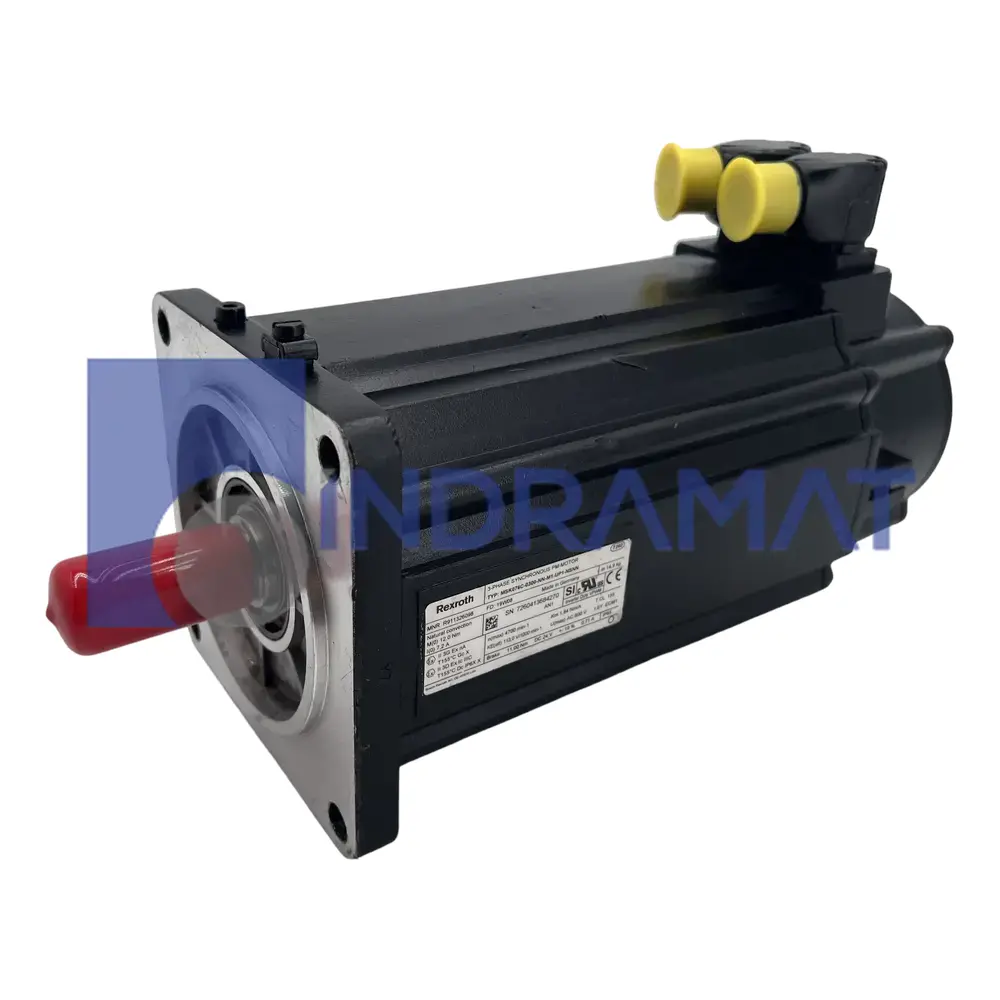
MSK076C-0300-NN-M1-UP1-NNNN
MSK IndraDyn S Synchronous Motors
Technical Specifications
Cooling
Natural convection
Design
Standard
Encoder Connector
Rotatable, 240°
Encoder Interface
Hiperface
Encoder Resolution
128 signal periods
Encoder Technology
Optical
Encoder Turn Type
Multiturn Absolute
Holding Brake Torque
11 Nm
Motor Length
C
Motor Size
076
Shaft Type
Shaft with keyway
Winding Code
0300
Frequently Asked Questions
How does the multiturn Hiperface encoder in MSK076C-0300-NN-M1-UP1-NNNN enhance absolute positioning and startup behavior?
Its optical multiturn encoder with Hiperface transmits sine/cosine tracks and digital data, so absolute position is available immediately after power-up without homing. Its 128 signal periods improves servo loop stiffness and low-speed smoothness.
What is the functional advantage of the 240° rotatable power/feedback connectors on MSK076C-0300-NN-M1-UP1-NNNN during machine integration?
The connectors can be rotated to align cable exit with the preferred conduit path for minimizing bend radius stress and simplifying panel routing. Its orientation flexibility also helps maintain IP65 sealing when union nuts are properly torqued.
Why is a keyed shaft specified, and how does it affect coupling selection for MSK076C-0300-NN-M1-UP1-NNNN?
Its shaft with keyway per DIN standards provides positive torque transmission and repeatable phasing for timing pulleys or rigid couplings. It reduces slip risk under transient torque and eases service alignment compared to plain interference fits.
How should the 11 Nm electrically released holding brake be sized relative to the 43.5 Nm peak torque on MSK076C-0300-NN-M1-UP1-NNNN?
The holding brake is designed for static holding and emergency stop positioning not for continuous dynamic braking. Its brake sizing resist axis backdriving under gravity or external load, while dynamic deceleration remains the drive’s responsibility.
What encoder resolution and interface considerations exist when integrating MSK076C-0300-NN-M1-UP1-NNNN with third-party controllers?
The standard optical encoder provides 128 signal periods Hiperface feedback, many controllers accept its sin/cos plus serial protocol. Its cable shielding, excitation and interpolation settings needs matching to avoid velocity ripple and phase lag.
Common Misspellings
MSK 076C-0300-NN-M1-UP1-NNNN
MSK-076C-0300-NN-M1-UP1-NNNN
MSK076C 0300 NN M1 UP1 NNNN
MSK076C-0300-NN-M1-UP1
MSK076C-0300-NN-MI-UPI-NNNN
MSK076C0300NNM1UP1NNNN
MSKO76C-0300-NN-M1-UP1-NNNN
MSKO76C-O3OO-NN-M1-UP1-NNNN
MSK76C-0300-NN-M1-UP1-NNNN
Internal Product Review
The MSK076C-0300-NN-M1-UP1-NNNN synchronous servomotor from Bosch matches IP65 construction with a multiturn Hiperface encoder of 128 signal periods and possess 240° rotatable connectors for feedback connectivity. It offers flange mounting and comes with a balanced keyed shaft. This motor has an 11 Nm of brake system that aids secure integration and its rated speed is 4700 rpm that makes it ideal for usage in packaging, machine tools, printing and food-processing lines.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MSK076C-0300-NN-M1-UP1-NNNN.
 Want to