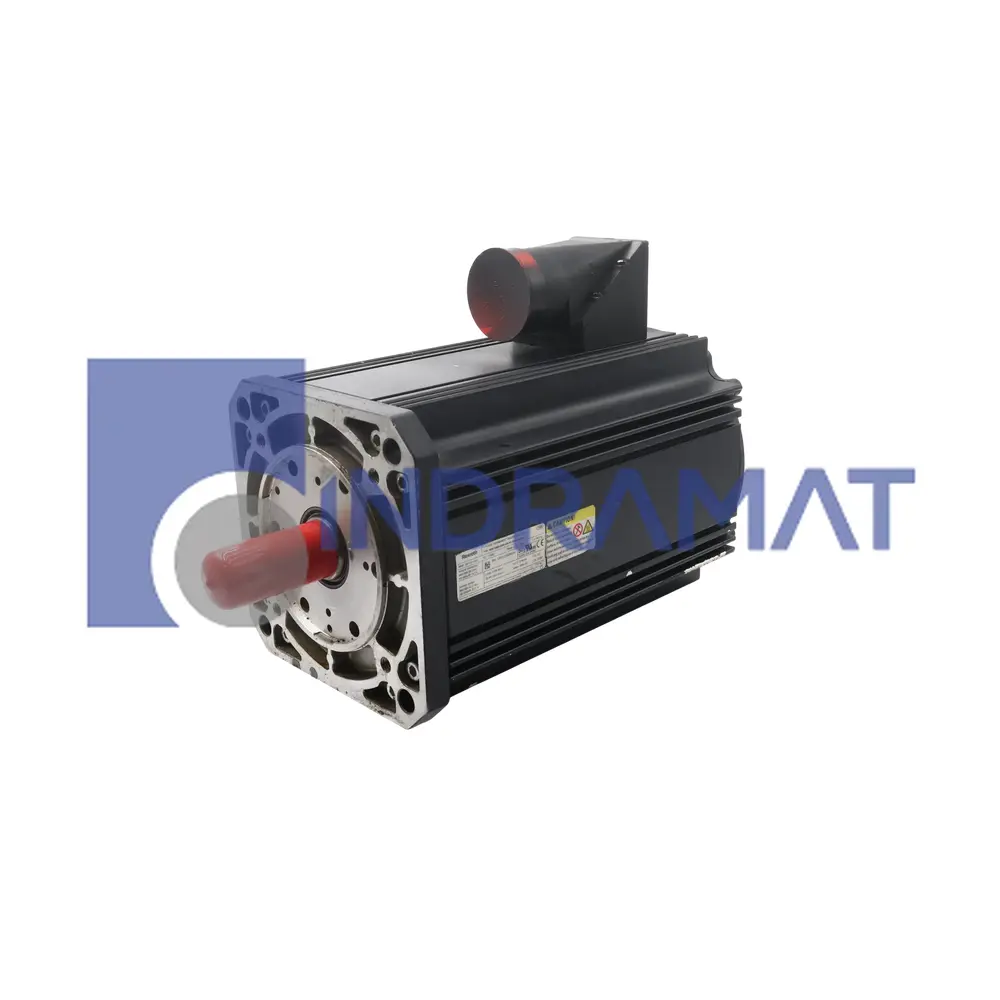
MSK100B-0200-NN-M1-RP1-NNNN
MSK IndraDyn S Synchronous Motors
Technical Specifications
Cooling
Natural convection
Power Connector
Right-Side
Encoder Technology
Optical
Encoder Turn Type
Multiturn Absolute
Encoder Interface
Hiperface
Encoder Resolution
128 signal periods
Motor Length
B
Motor Size
100
Holding Brake
With holding brake, electrically-released
Holding Brake Torque
32 Nm
Design
Standard
Product Type
IndraDyn S Synchronous Servomotor
Shaft Type
Shaft with keyway
Rated Speed Code
0200
Continuous Current at Standstill 100 K
17.3 A
Continuous Torque at Standstill 100 K
33.0 Nm
Maximum Current
66.2 A
Maximum Torque
102.0 Nm
Winding Inductivity
7,600 mH
Frequently Asked Questions
Why use an electrically released 32 Nm holding brake, and how do I evaluate its suitability for vertical axes on MSK100B-0200-NN-M1-RP1-NNNN?
The spring-applied brake engages on loss of power for providing static holding to 32 Nm for parked or safe torque off states. It is important for vertical axes to confirm brake torque versus reflected load torque and follow Rexroth brake sizing guidelines.
What are typical mechanical load limits and coupling considerations for the MSK100B-0200-NN-M1-RP1-NNNN shaft with keyway?
The Rexroth data for MSK100-series show permissible axial force around 500 N with defined radial load curves; verify bearing variant. It is important to use backlash-free keyed couplings and align precisely to minimize bearing preload and encoder load.
How does the right-side power connector (RP1) on MSK100B-0200-NN-M1-RP1-NNNN affect cable routing and EMC compliance?
The right-side exit simplifies routing in right-hand cable trays and reduces bend-radius conflicts. It shields-360° termination and segregation from signal lines for conducted/radiated EMI control with Hiperface feedback.
What continuous/peak torque behavior should I expect when pairing MSK100B-0200-NN-M1-RP1-NNNN with IndraDrive in cyclic-duty packaging or printing tasks?
The plan around 33 Nm continuous at 100 K and 102 Nm peak for short bursts within thermal and current limits. Its duty-cycle-based thermal guides permissible overload duration and cooldown intervals.
How does the winding inductivity (7,600 mH stated for MSK100B-0200-NN-M1-RP1-NNNN) influence drive selection and current ripple?
Its inductance reduces current ripple at a given PWM frequency for easing drive current loop demands. It is recommended to ensure your IndraDrive can deliver the specified maximum current and bandwidth while maintaining stability across DC-bus and bus-capacitance conditions.
Common Misspellings
MSK100B0200NNM1RP1NNNN
MSK100B 0200 NN M1 RP1 NNNN
MSK-100B-0200-NN-M1-RP1-NNNN
Internal Product Review
The IndraDyn S MSK100B-0200-NN-M1-RP1-NNNN servomotor from Bosch Rexroth features a multiturn absolute optical encoder with Hiperface interface and a holding brake torque of 32 Nm. It delivers 33.0 Nm continuous torque and operates with natural convection cooling. This motor is commonly used in CNC machines, robotics, and printing automation.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MSK100B-0200-NN-M1-RP1-NNNN.
 Want to