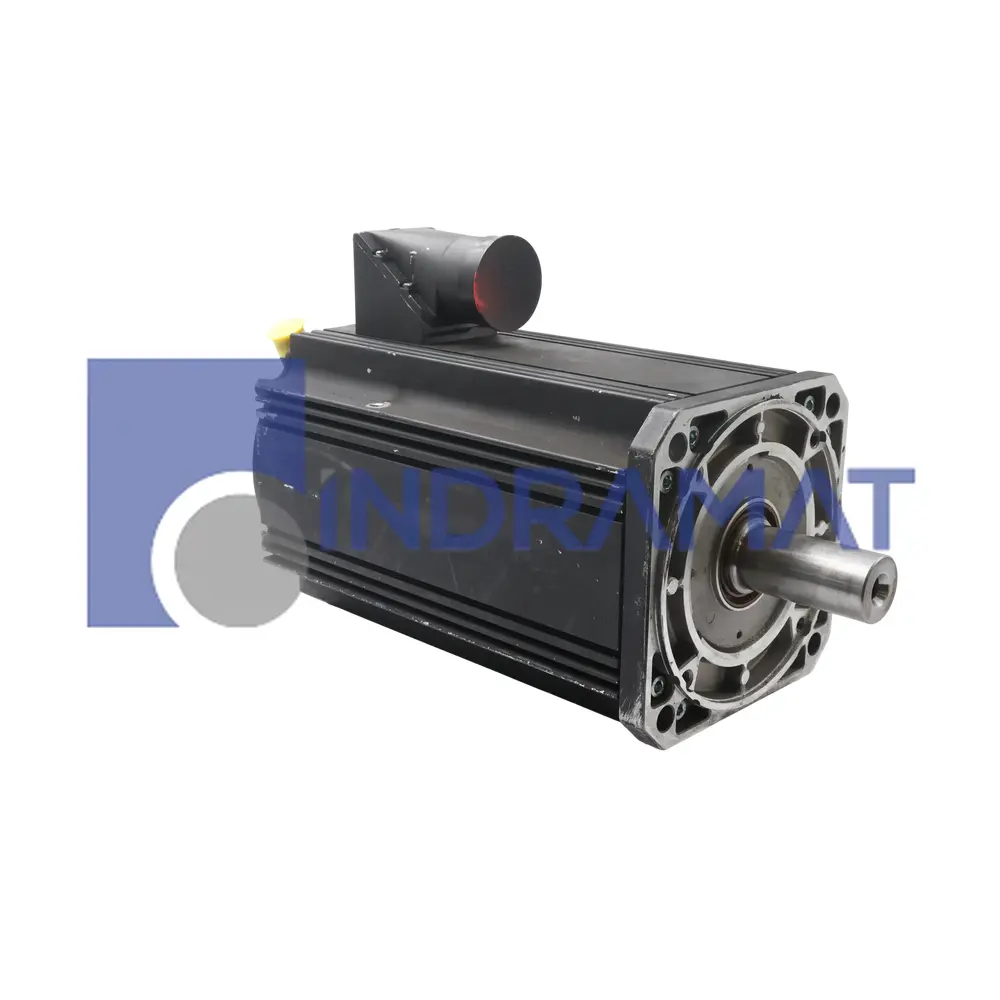
MSK101D-0300-FN-S1-BP0-NNNN
MSK IndraDyn S Synchronous Motors
Technical Specifications
Cooling
Liquid cooling
Power Connector
B-Side
Encoder Technology
Optical
Encoder Turn Type
Singleturn
Encoder Interface
Hiperface
Encoder Resolution
128 signal periods
Motor Length
D
Motor Size
101
Holding Brake
Without holding brake
Design
Standard
Product Type
IndraDyn S Synchronous Servomotor
Shaft Type
Shaft with keyway
Rated Speed Code
0300
Continuous Current at Standstill 100 K
34.9 A
Continuous Torque at Standstill 100 K
57.0 Nm
Maximum Current
137.7 A
Maximum Torque
160.0 Nm
Winding Inductivity
3,200 mH
Frequently Asked Questions
What are the installation constraints due to the winding inductance of 3,200 mH?
The relatively high inductance slows current build-up, which may limit torque responsiveness at higher dynamics unless the drive compensates with voltage headroom and control tuning. In multi-axis systems, cable length and stray inductance add further phase lag, so keep leads short and properly sized.
How does the Hiperface optical singleturn encoder with 128 signal periods impact precision?
The 128 signal periods means there are 128 cycles per revolution to interpolate within, giving fine angular resolution when used with interpolation in the drive. Combined with absolute positioning, this approach simplifies initialization while retaining high dynamic control accuracy.
In robotics or CNC, how does the lack of a holding brake influence safety or system design?
Without a holding brake, the motor cannot passively resist load when unpowered, so you’ll need external mechanical locks or zero-torque safety strategies. In multi-axis machines, you might require brakes on gearboxes or cams to maintain fail-safe stance.
What mechanical stresses (radial/axial) can the rotor support, and how should shaft loads be managed?
In the MSK series, allowable radial and axial shaft loads are specified in the Project Planning Manual; exceeding them shortens bearing life or causes misalignment. Always apply loads within those limits and use proper bearings or couplings to isolate misalignment.
How do cable routing and EMC considerations affect performance and noise in a liquid-cooled servo?
High currents (peak ~137.7 A) demand low-impedance, screened cables to reduce voltage drop and noise coupling; avoiding cable loops and keeping cable separation from fragile analog signals is critical. Use common-mode chokes and grounding strategies to suppress noise back into the drive.
Common Misspellings
MSK101D0300FNS1BP0NNNN
MSK101D 0300 FN S1 BP0 NNNN
MSK-101D-0300-FN-S1-BP0-NNNN
Internal Product Review
The MSK101D-0300-FN-S1-BP0-NNNN servomotor by Bosch Rexroth is used in CNC machines, robotics, and packaging systems. It delivers 57.0 Nm continuous torque at standstill and 160.0 Nm maximum torque. The motor features liquid cooling, a keyed shaft, and an optical singleturn encoder with Hiperface interface.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MSK101D-0300-FN-S1-BP0-NNNN.
 Want to