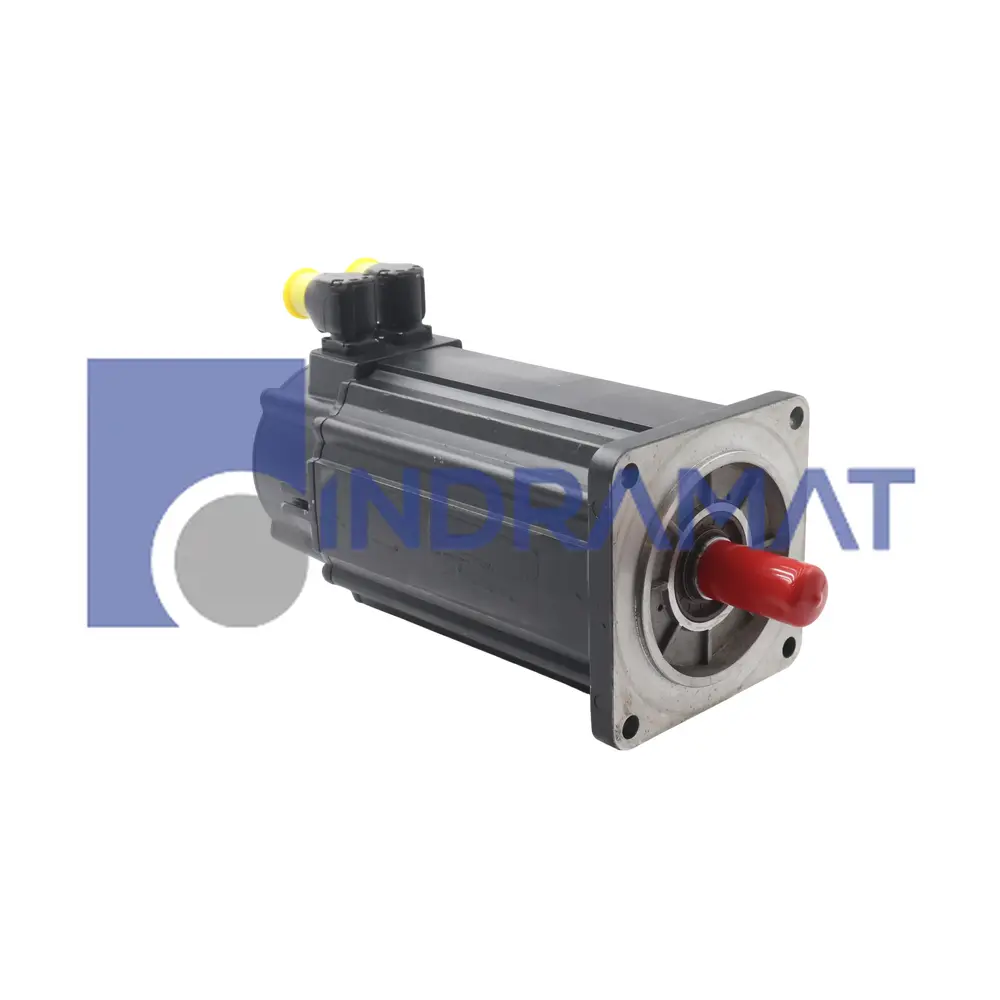
R911318098 (MSK076C-0450-NN-M1-UG0-NNNN)
MSK IndraDyn S Synchronous Motors
Technical Specifications
Encoder
Optical
Winding Code
450
Increments
Multiturn hiperface with 128 increments
Shaft
Plain with standard shaft sealing ring
Cooling Mode
Natural Convection
Safety Warning
Incorrect usage may cause severe injury or death
Frequently Asked Questions
How does the 4,700 mH winding inductivity affect current ripple, bandwidth, and EMI in MSK076C-0450-NN-M1-UG0-NNNN?
It increases the electrical time constant that smooths phase current and attenuates PWM harmonics, which lowers ripple and conducted emissions. Its tradeoff is reduced current-loop bandwidth; tune IndraDrive current gains and switching frequency accordingly to maintain dynamic torque fidelity.
Why is an optical, multiturn absolute encoder (128 periods) with Hiperface advantageous on MSK076C-0450-NN-M1-UG0-NNNN for coordinated axes?
The absolute multi-turn feedback eliminates homing to preserve position across power cycles and enables deterministic startup. Its Hiperface combines high-resolution Sin/Cos incremental signals with a bidirectional serial channel for enabling fine interpolation and parameter readout for tight servo loops.
What commissioning and EMC benefits come from the 240° rotatable encoder connector on MSK076C-0450-NN-M1-UG0-NNNN?
The swivel connector lets you direct the cable to maintain bend radius, minimize strain and keep shield terminations short. Its optimized cable egress helps reduce loop area and susceptibility for improving noise immunity and easing panel or gantry routing.
How does natural-convection cooling influence duty-cycle planning for MSK076C-0450-NN-M1-UG0-NNNN?
Its heat rejection relies on mounting surface and ambient airflow, so continuous torque is sensitive to enclosure design and temperature. For cyclical overloads or restricted ventilation, derate or select forced-cooling variants or add external airflow to stabilize winding temperature.
How does the plain shaft on MSK076C-0450-NN-M1-UG0-NNNN affect coupling selection and torsional dynamics?
The use of zero-backlash, torsionally stiff couplings matches inertia ratio and misalignment tolerances. It is important to analyze torsional resonances and balancing, as precise alignment reduces bearing loads and enables higher control bandwidth without chatter.
Common Misspellings
MSK 076C-0450-NN-M1-UG0-NNNN
MSK-076C-0450-NN-M1-UG0-NNNN
MSK076C 0450 NN M1 UG0 NNNN
MSK076C-0450-NN-M1-UG0
MSK076C-0450-NN-MI-UG0-NNNN
MSK076C0450NNM1UG0NNNN
MSKO76C-0450-NN-M1-UG0-NNNN
MSKO76C-O45O-NN-M1-UGO-NNNN
msk076c-0450-nn-m1-ug0-nnnn
MSK076C0450NNM1UG0NNNN
MSK076C 0450 NN M1 UG0 NNNN
MSK76C-0450-NN-M1-UG0-NNNN
Internal Product Review
The Bosch Rexroth’s IndraDyn series servomotor MSK076C-0450-NN-M1-UG0-NNNN delivers precise motion with 13.5 Nm torque at standstill and up to 43.5 Nm of peak torque. Its feedback system is an optical multiturn encoder and it commissions via 240° rotatable connector. This motor uses natural-convection cooling and its shaft has a plain design. It has 4700 mH of inductance for streamline integration in packaging, printing, machine tools and handling/robotics.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MSK076C-0450-NN-M1-UG0-NNNN.
 Want to