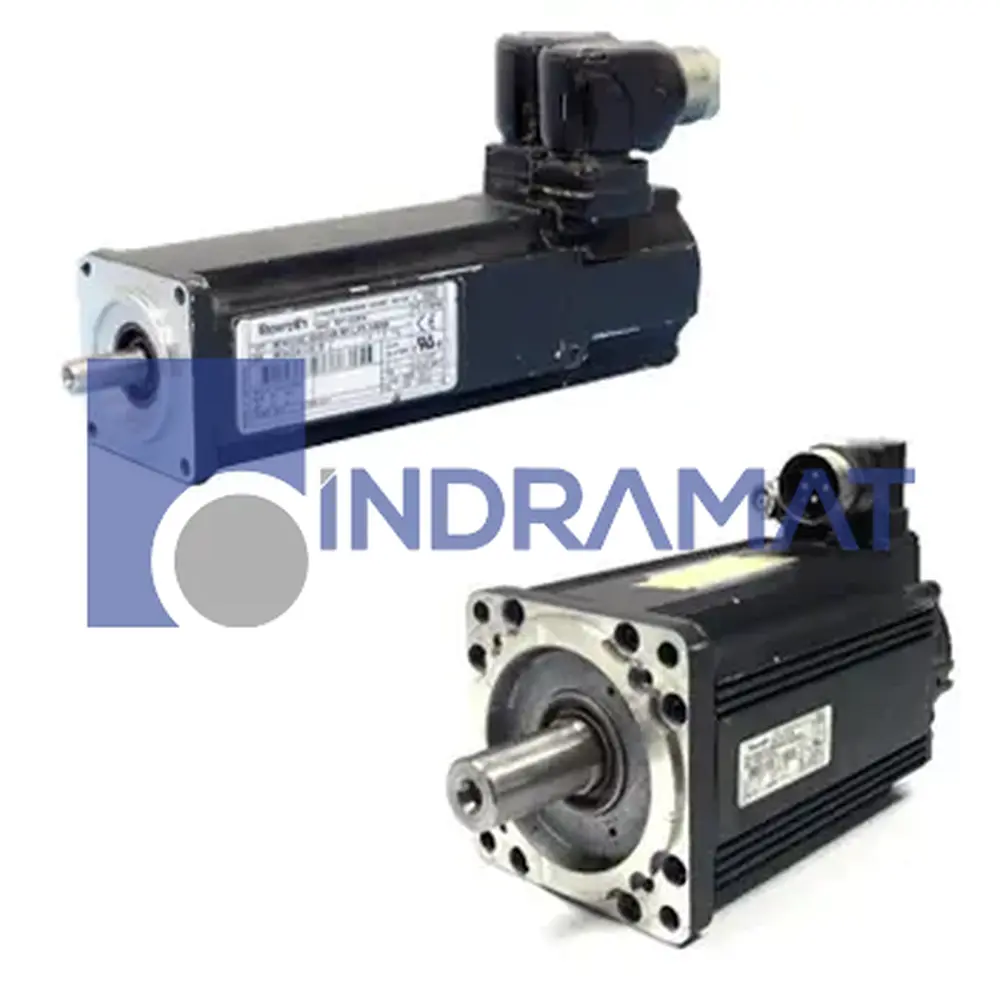
R911337854 (MSK071C-0450-FN-S1-UP0-NNNN)
MSK IndraDyn S Synchronous Motors
Technical Specifications
Application
Industrial and commercial
Compatible With
DDS Controllers
Encoder Type
Integrated single-turn
Max Encoder Speed
12000 RPM
Encoder Current
60 milliamps
Encoder Voltage
7 to 12 Volts DC
Shaft Type
Keyway and seal
Heat Dissipation
0.75 kilowatts
Cooling Method
Liquid Cooling
Coolant Duct Volume
0.04 liter
Optimal Operating Temperature
0 to 40 degrees Celsius
Minimum Coolant Flow Rate
1.1 liters per minute
Design
Standard
Connector Rotation
240 degrees in either direction
Holding Brake
Not Available.
Frequently Asked Questions
How does the liquid-cooling path in MSK071C-0450-FN-S1-UP0-NNNN influence continuous duty and thermal stability on tightly loaded axes?
The liquid cooling removes copper and core losses efficiently for helping the motor sustain its 10.4 A standstill current with less derating over long cycles. It preserves servo stiffness and position repeatability in dense enclosures and elevated ambient conditions.
How does the 6,700 mH winding inductivity affect current ripple, drive selection, and current-loop tuning?
The higher inductivity reduces PWM ripple and harmonic heating but slows current rise time, which can limit very fast torque steps. Its drive with adequate DC-bus voltage/switching frequency and retune current-loop bandwidth balances responsiveness and thermal behavior.
What is the practical value of the 240° rotatable encoder connector for cabinet and cable-chain design?
The adjustable exit angle eases routing in constrained machines for reducing bend stress and avoiding EMI-sensitive zones. It also helps maintain service loops for vibration isolation while keeping minimum bend radius within cable specifications.
What controller/feedback compatibility considerations exist when interfacing the motor’s Hiperface encoder with Rexroth drives?
The Rexroth IndraDrive controllers auto-detect Hiperface encoders on the designated feedback slot for streamlining setup and diagnostics. It is important to ensure firmware supports S1 Hiperface then select the correct interpolation and verify STO/SafeMotion options as needed.
How should 14.0 Nm standstill torque and 44.0 Nm peak on MSK071C-0450-FN-S1-UP0-NNNN be used for axis sizing and safety margins?
The standstill torque for thermal/RMS checks and the peak for acceleration transients for applying duty-cycle-weighted RMS calculations. It maintains margin for friction variance and tool wear.
Common Misspellings
MSK071C0450FNS1UP0NNNN
MSK071C 0450 FN S1 UP0 NNNN
MSK-071C-0450-FN-S1-UP0-NNNN
MSK71C-0450-FN-S1-UP0-NNNN
Internal Product Review
The Indramat’s MSK IndraDyn series servomotor MSK071C-0450-FN-S1-UP0-NNNN uses liquid cooling for thermal management and includes a mechanically balanced keyed design of shaft. It has no holding brake and possess a singleturn encoder of 128 periods for streamlined feedback. This motor is built to deliver 14.0 Nm of stall and 44.0 Nm peak torque to fit into machine-tool, robotics and printing/packaging axes.


Shipping & Payment Options
Warranty
Repair
 We offer a repair service for the MSK071C-0450-FN-S1-UP0-NNNN.
 Want to